Why Add the Unitree Dex2/5 to Your G1 or R1?
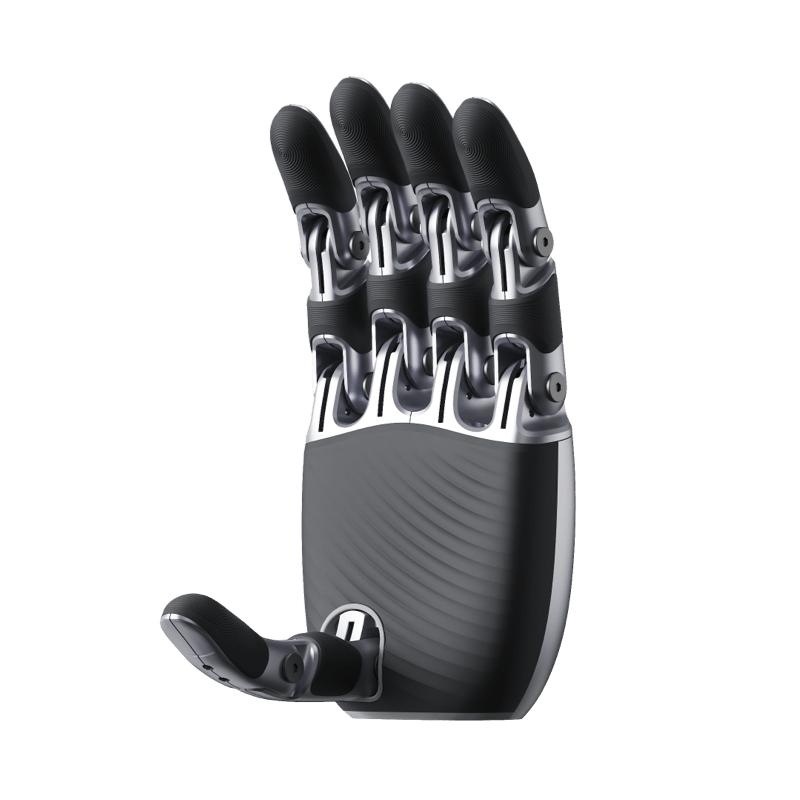
The Unitree Dex2/5 is a Gala-style tendon-driven dexterous hand built for Unitree’s G1 and R1 humanoid platforms. It packs 10 degrees of freedom across two actuated joint groups into a hand that weighs just 365g, giving G1 and R1 units the fine manipulation needed for grasping, tool use, and dexterous handling tasks that a simple gripper cannot perform. Full specifications are published on Unitree’s official product page.
Unlike a bolt-on end effector, the Dex2/5 routes its tendon-rope transmission and wiring inside the hand itself, so it mounts cleanly onto the G1 or R1 wrist without exposed cables. For teams already running G1 or R1 EDU units, the Dex2/5 is a straightforward upgrade path to add real manipulation capability without redesigning the arm.
Key Features
- Gala-Style Tendon-Driven Actuation: 10-DOF hand with 2 actuated joint groups (thumb plus four fingers on shared DOF), driven by an internal tendon-rope transmission instead of exposed linkages.
- Compact and Lightweight: 365g and 151 × 70 × 63mm flat, sized to match the G1 and R1 wrist without adding excess arm-tip mass.
- Hidden Internal Wiring: Tendon ropes and signal wiring run beneath the hand’s outer “skin,” keeping the mechanism protected and cable-free at the wrist.
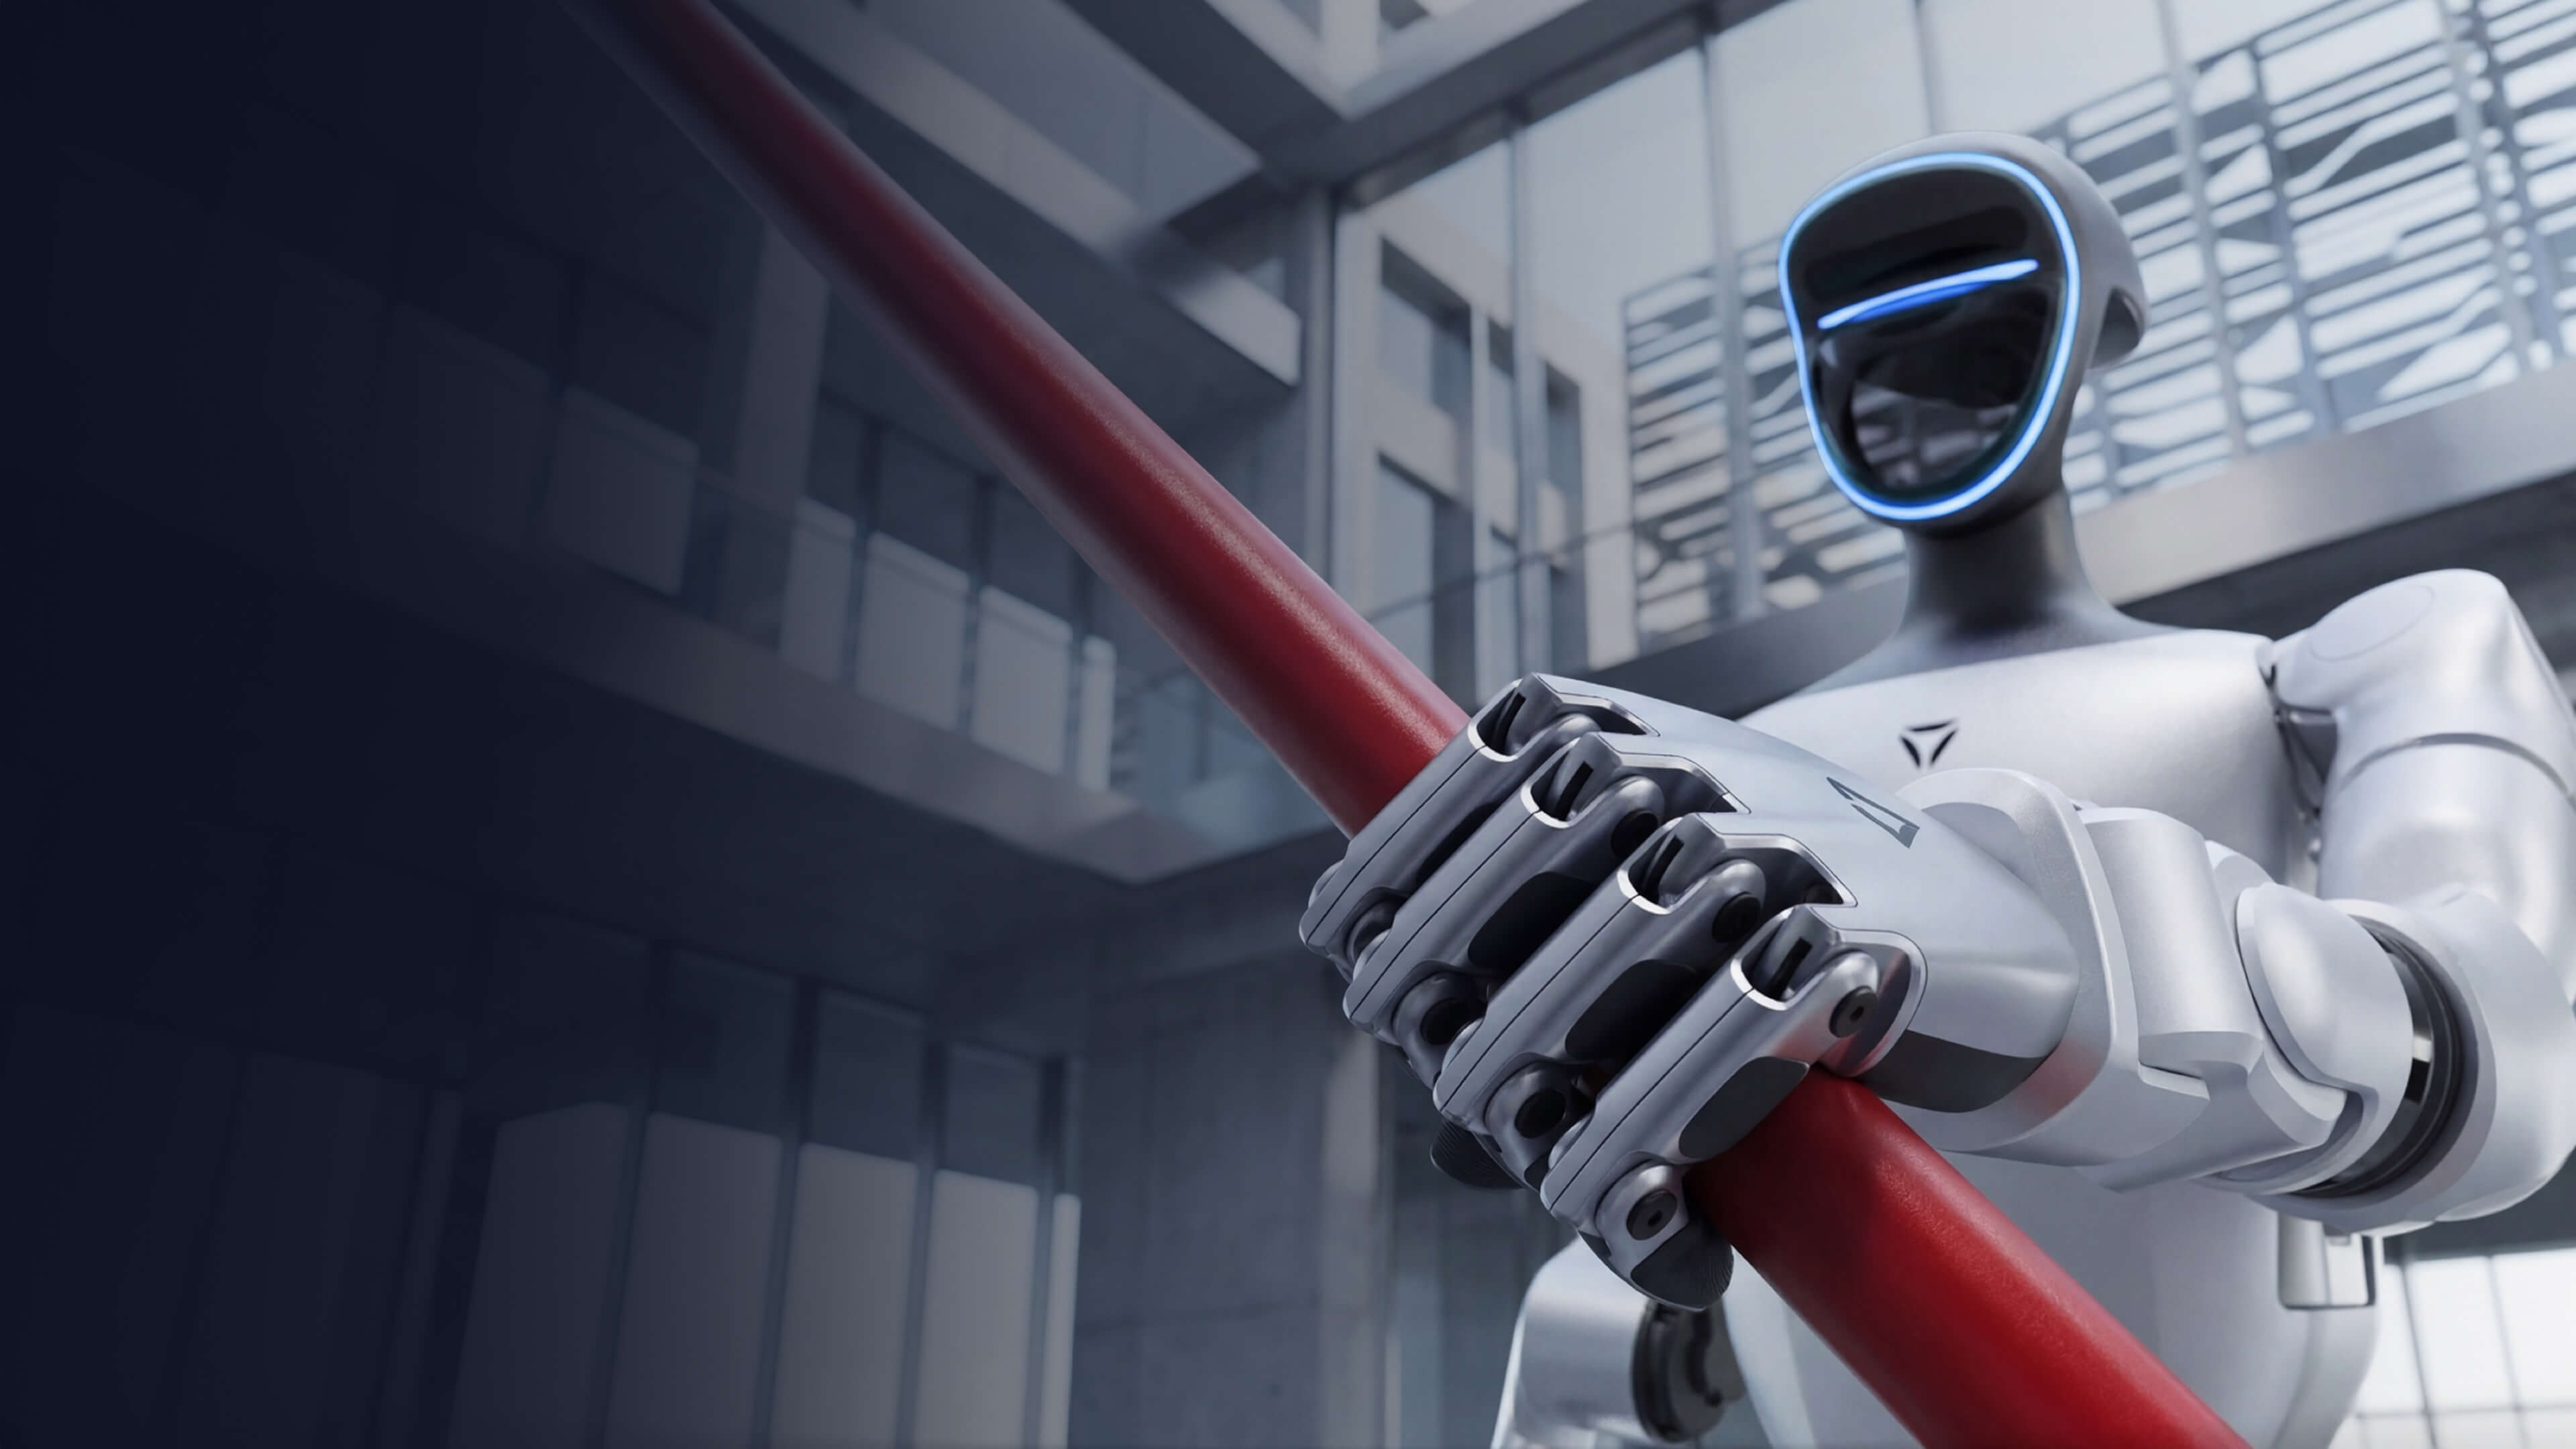
- Rugged, Impact-Resistant Build: Rated for 100,000+ fatigue cycles and 100+ drop tests, built to survive repeated use in lab and demo environments.
- Full Perceptual Feedback: Reports joint mode, position, velocity, torque, temperature, voltage, and current over RS485 at 1000Hz, with adjustable stiffness and damping.
Specifications
| Item | Specification |
|---|---|
| Product Name | Unitree Dex2/5 Dexterous Hand |
| Degrees of Freedom | 10-DOF (2 actuated joint groups) |
| Weight | 365 g |
| Dimensions (flat) | 151 × 70 × 63 mm |
| Finger Configuration | 1 thumb + 4 fingers (shared DOF) |
| Joint Angles | Thumb: 0–42° & 0–105°; Four fingers: 0–88° & 0–105° |
| Grip Speed | ≥ 0.5 s minimum full fist clench |
| Minimum Grip Diameter | 8 mm |
| Fingertip Force | Thumb 15 N; four fingers combined 15 N |
| Operating Voltage | 24V–60V |
| Current Draw | 0.1A static / 1.5A max @ 58V |
| Communication | RS485 interface, 1000Hz update rate |
| Operating Temperature | -20°C to 60°C |
| Max Load Capacity | 1.5 kg |
| Durability | 100,000+ fatigue cycles; 100+ drop tests |
| Compatible Robots | Unitree G1, Unitree R1 |
Compatible G1 & R1 Models
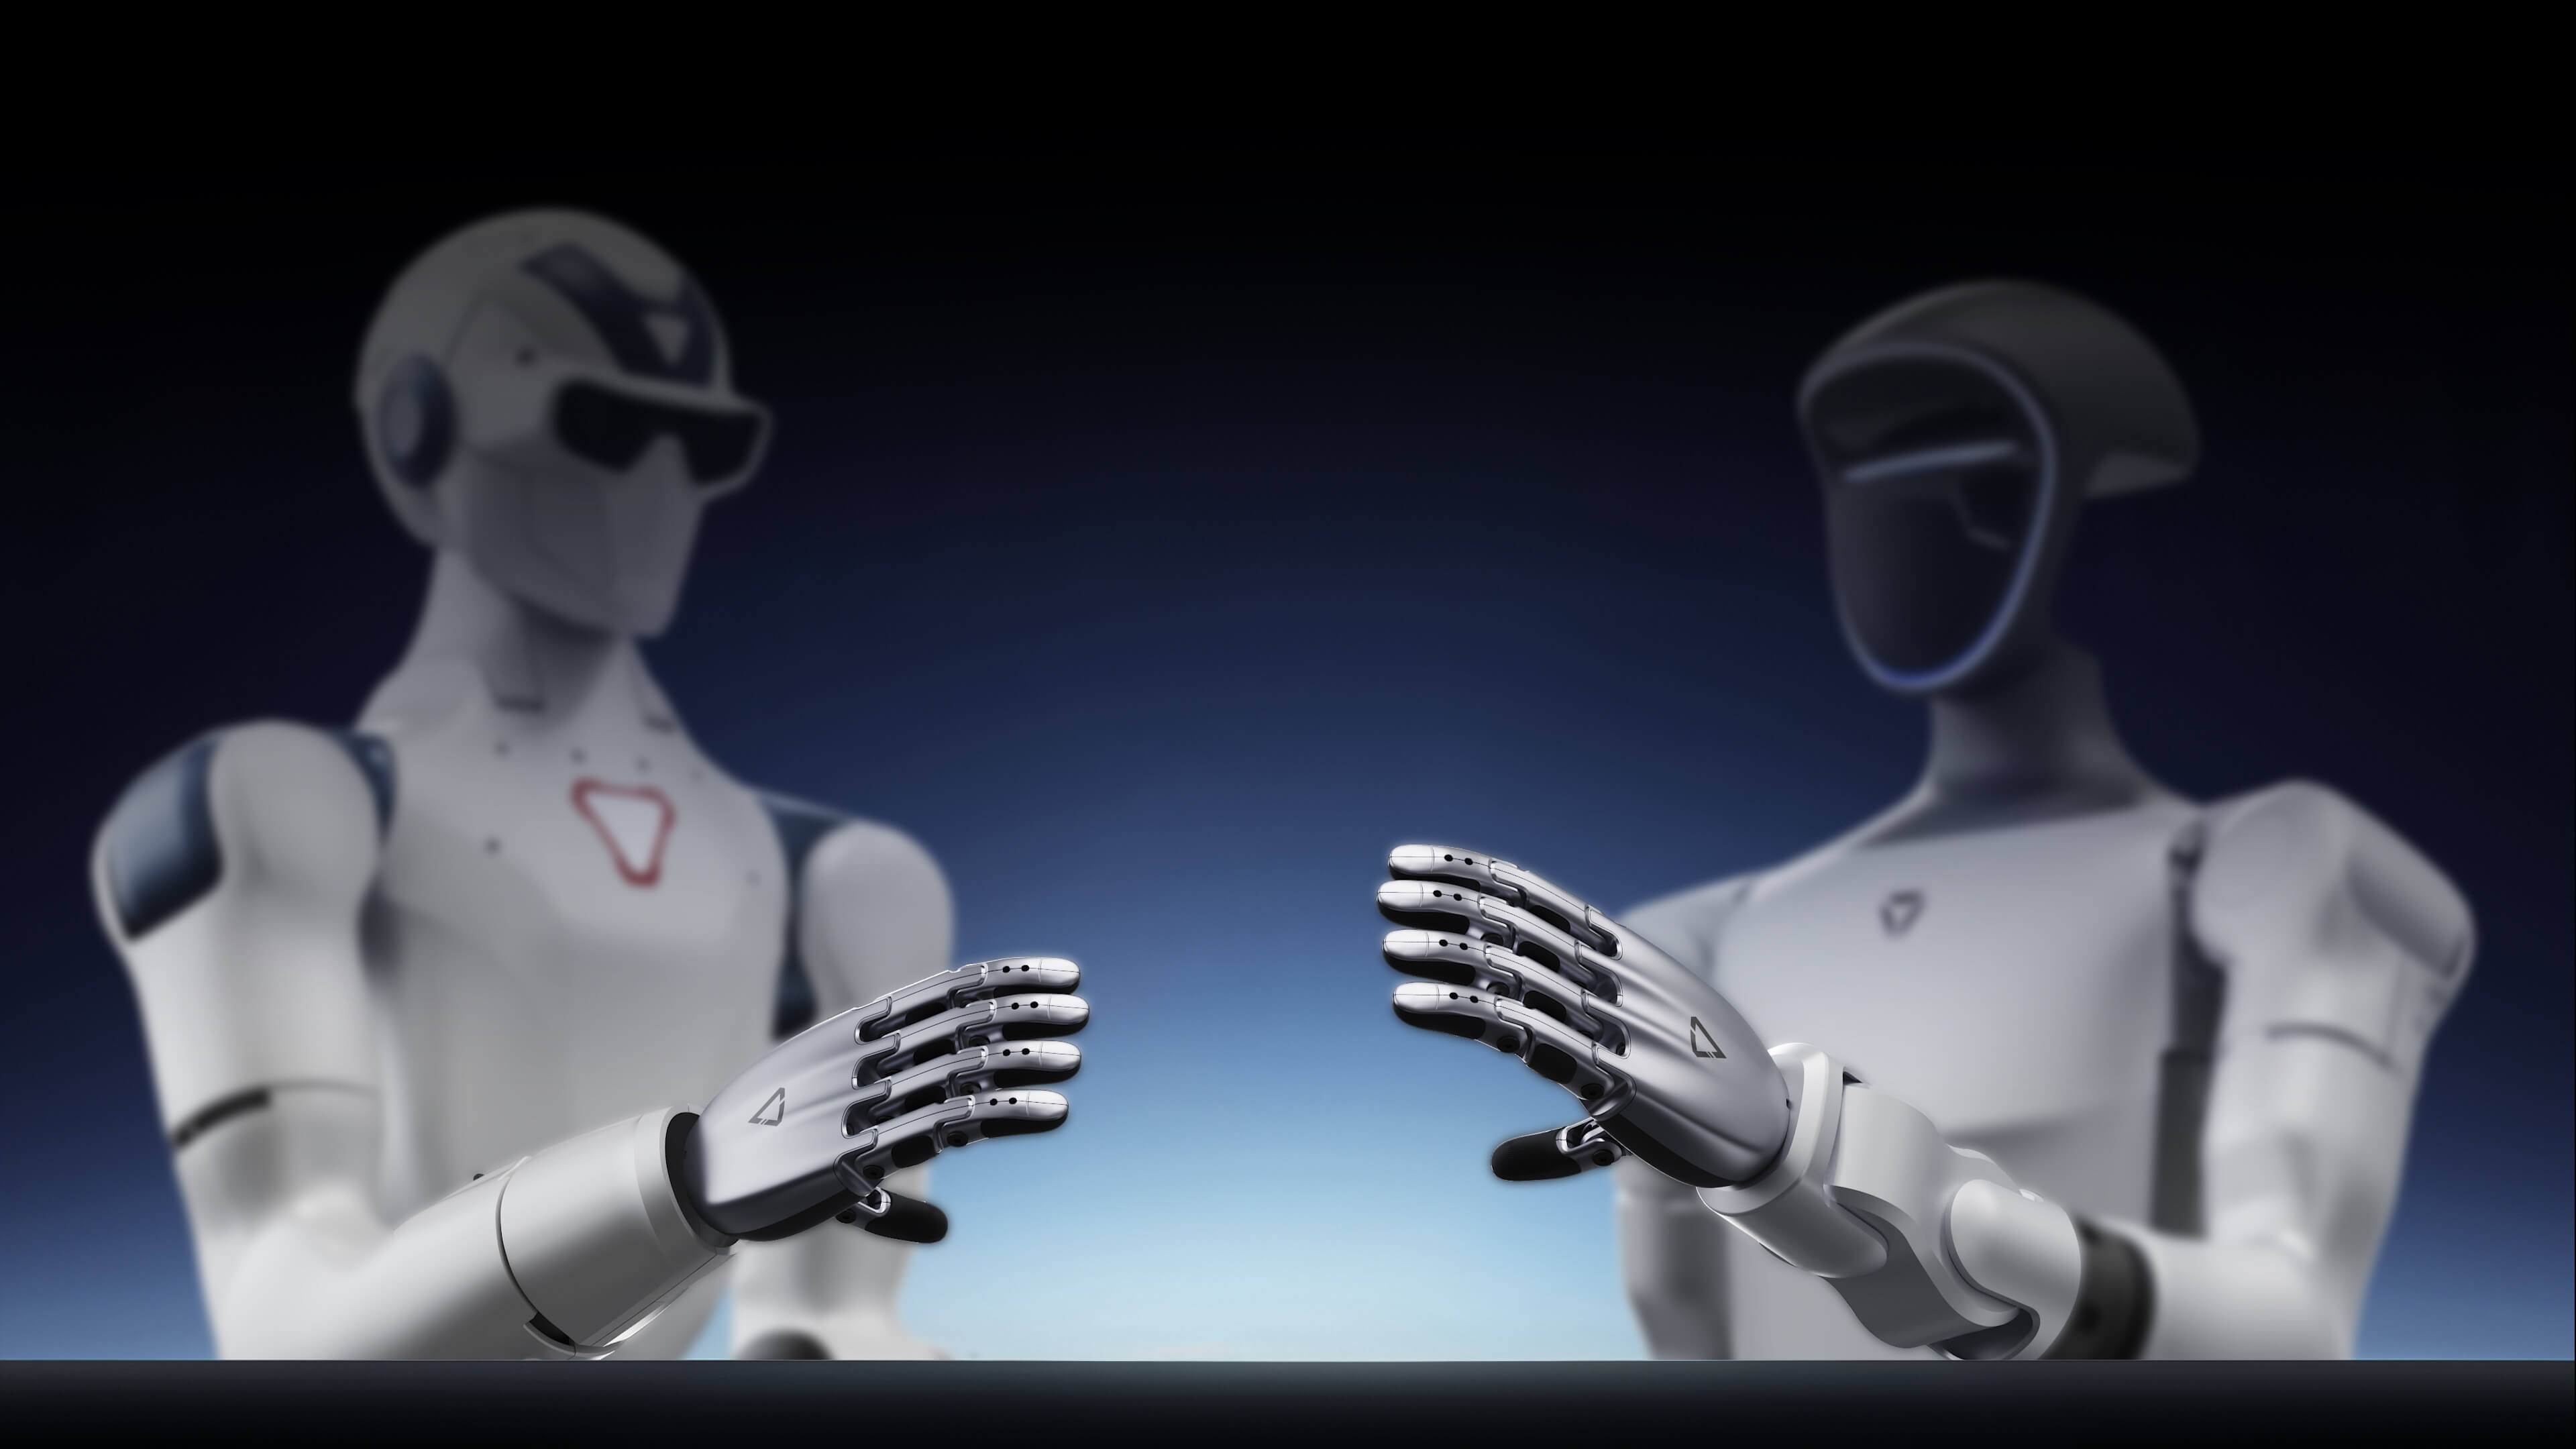
The Dex2/5 is designed to mount on both the Unitree G1 and Unitree R1 humanoid platforms in place of the standard end effector. It suits G1 units such as the G1 Basic and G1 EDU-tier robots like the G1 EDU Standard-U1 that need a dedicated manipulation hand, as well as R1 units including the R1 Basic and R1 EDU Standard Edition for teams building hand-focused demos or research workflows.
Installation & Use Cases
The Dex2/5 mounts to the G1 or R1 wrist as a drop-in replacement for the robot’s default hand or gripper, without modifying the arm’s core hardware. Once attached, the hand’s RS485 interface and joint-level feedback let existing G1/R1 control stacks read hand state and send finger commands at up to 1000Hz.
This makes the Dex2/5 a good fit for teleoperation research, grasping and manipulation studies, tool-use demonstrations, and any application where a G1 or R1 needs to pick up, hold, or operate objects rather than simply gesture or point. Teams pairing the Dex2/5 with onboard AI compute, such as the G1 Docking Station, can run local inference for grasp planning directly on the robot.
Who Should Consider This Upgrade
This accessory suits robotics labs, universities, and research teams running G1 or R1 units for manipulation-focused work, as well as demo and exhibition teams that want a robot capable of gripping tools or props with visible finger articulation rather than a simplified gripper. If you are unsure which G1 or R1 configuration your Dex2/5 order should ship with, reach out to our team with your robot model before purchasing.