Why Add the Unitree Dex1-1 to Your Humanoid or Robotic Arm?
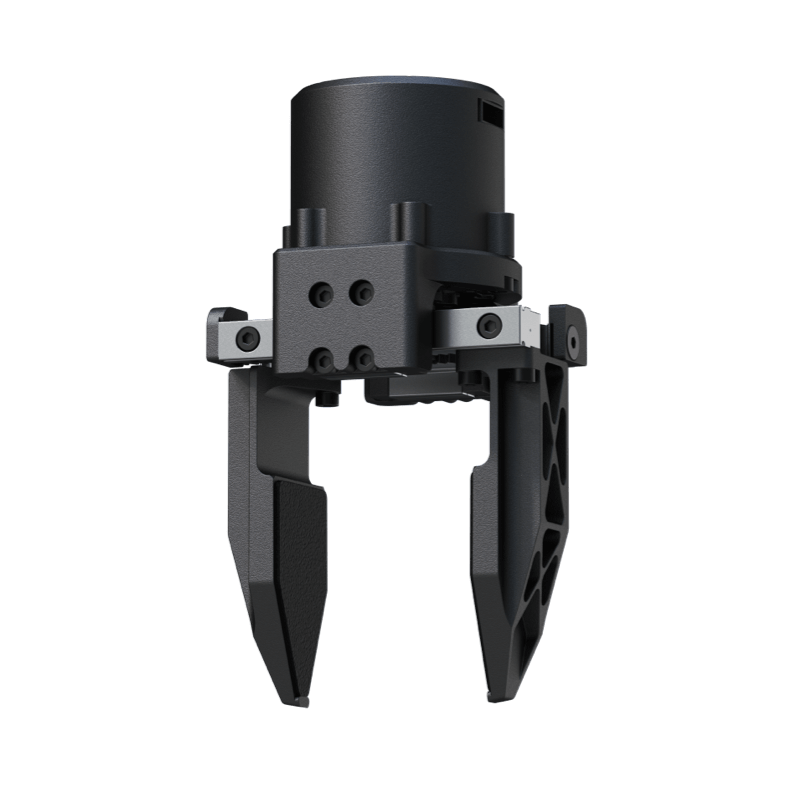
The Unitree Dex1-1 is a compact 2-finger parallel gripper designed as a fast, cost-effective manipulation end effector for Unitree’s G1, H2, and R1 humanoid platforms, and it also mounts to third-party robotic arms via its standard bolt pattern. Full specifications are published on Unitree’s official product page.
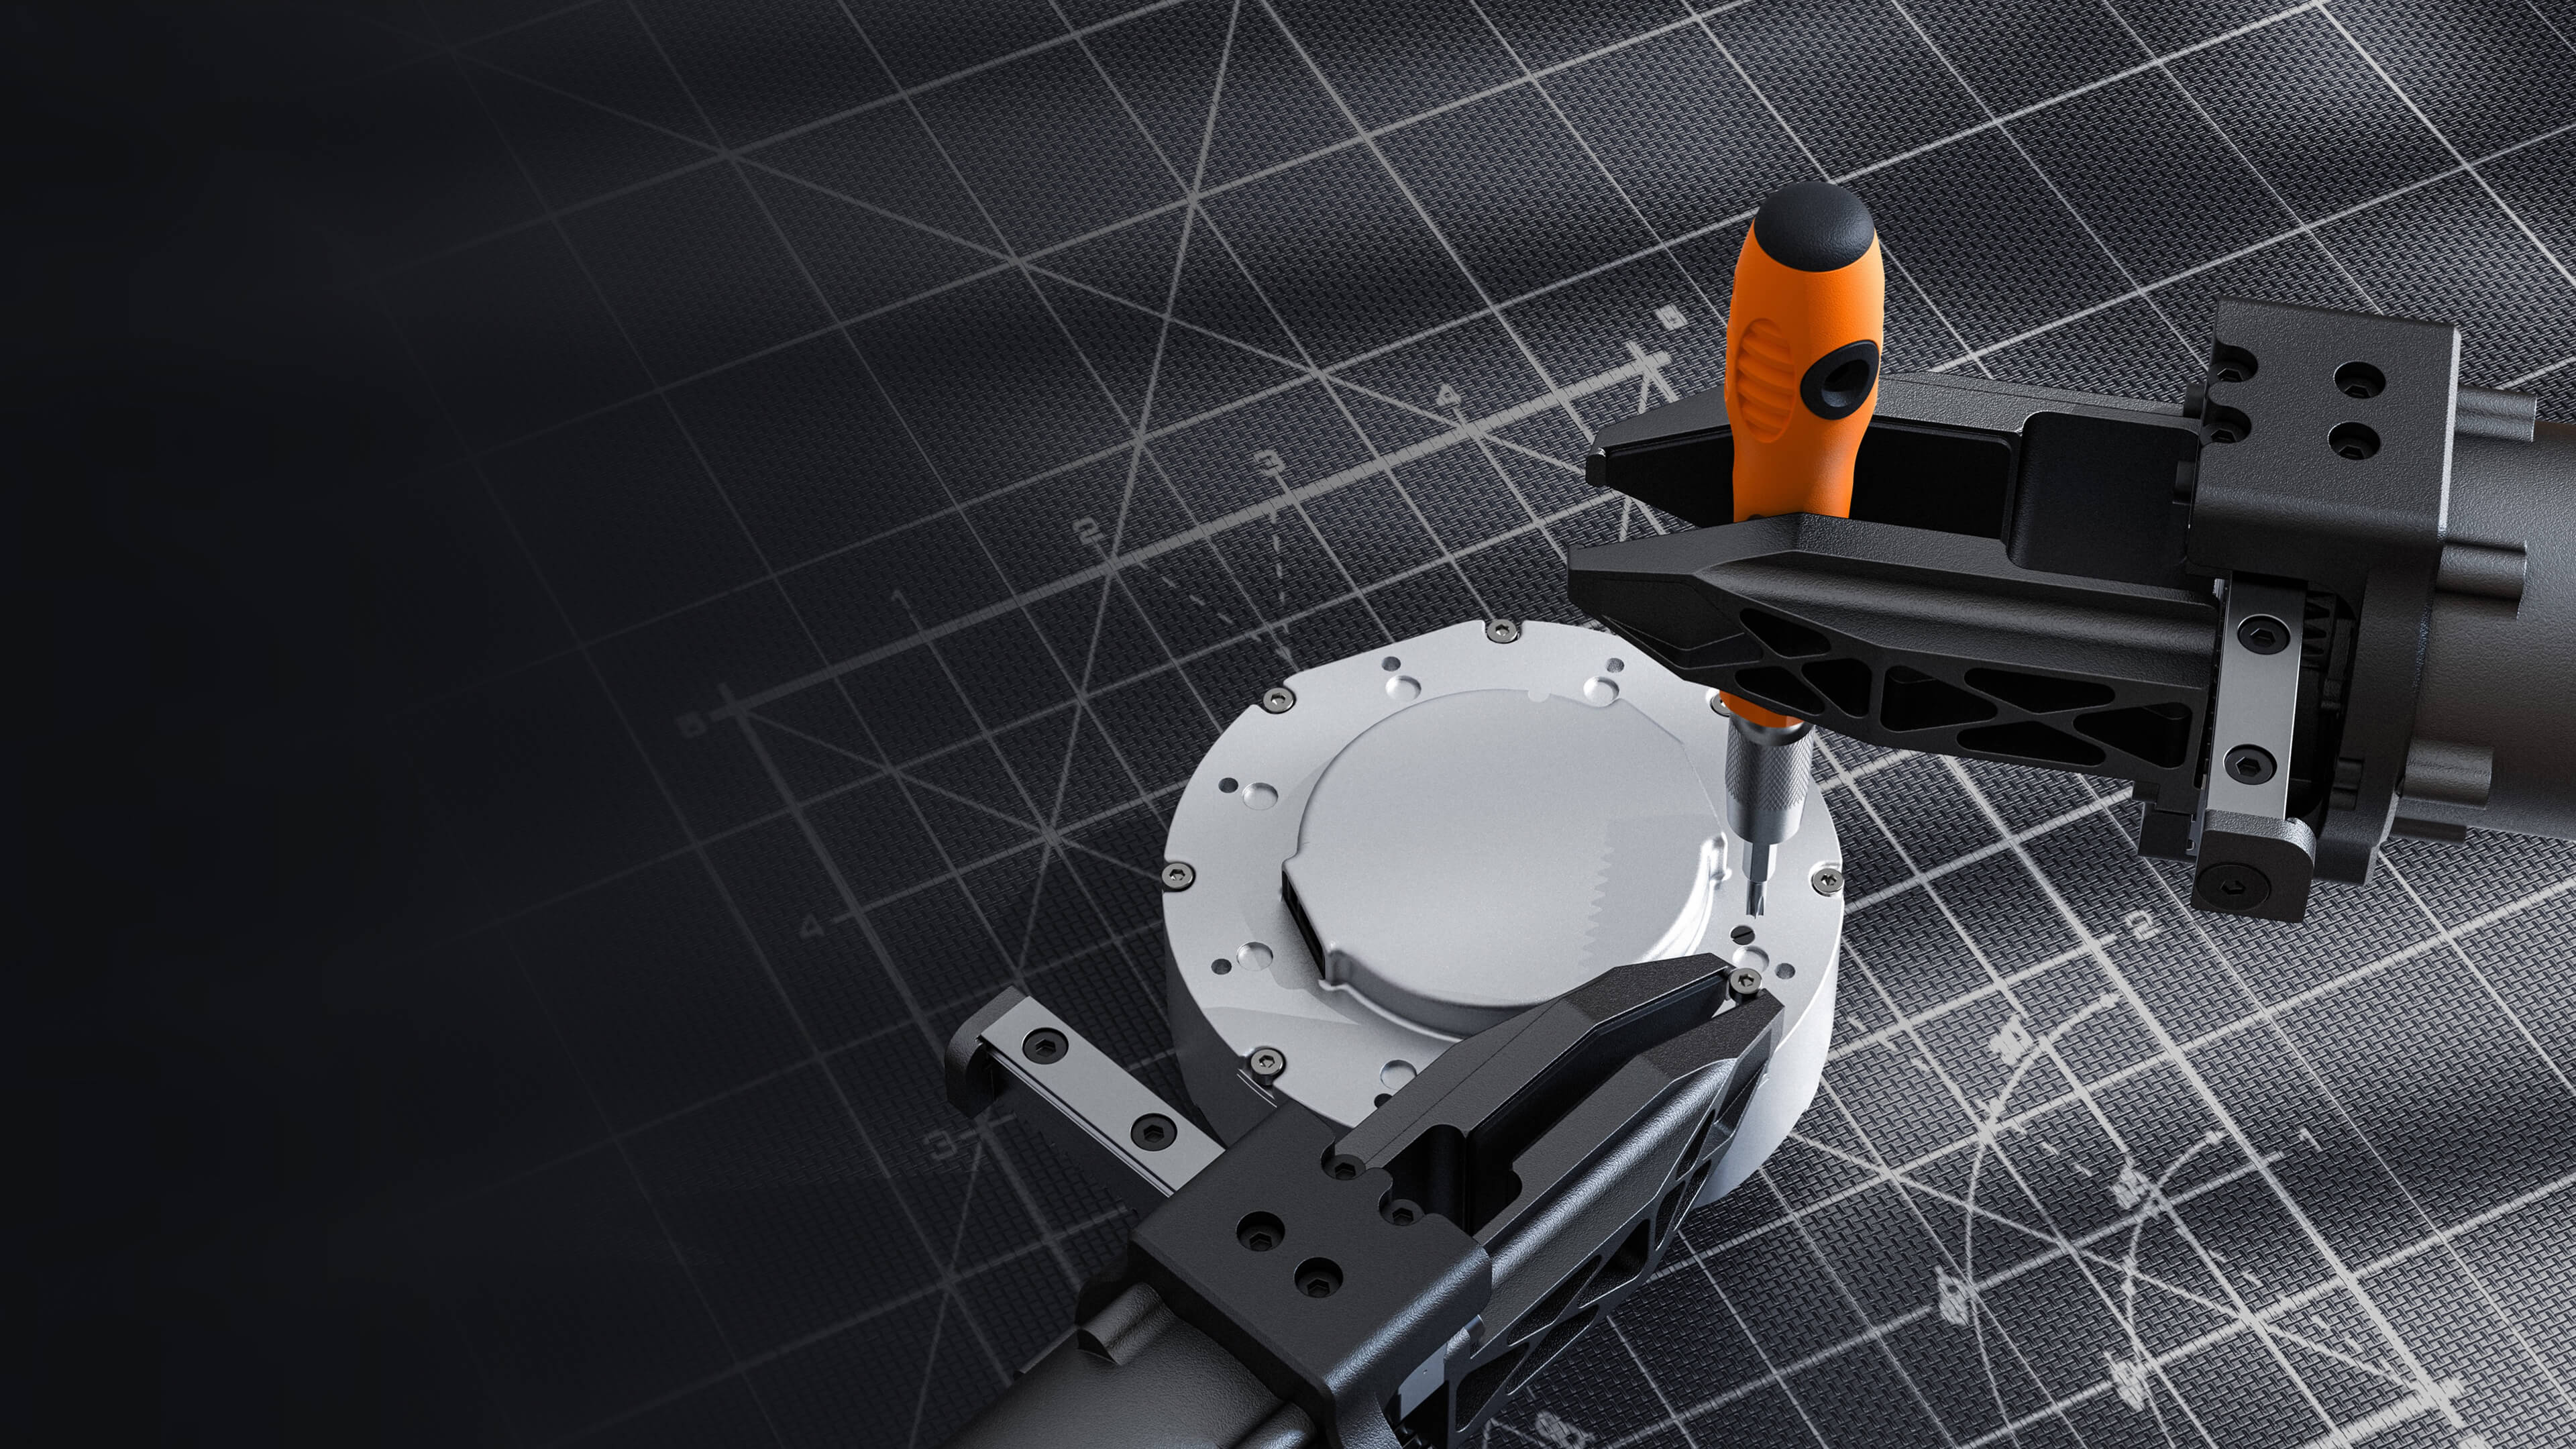
Unlike the tendon-driven Dex2/5, which mimics multi-finger human dexterity, the Dex1-1 uses a simple, rugged parallel-jaw design built for speed, repeatability, and adjustable grip force. It ships in a Standard version and an Advanced version with a built-in camera module for visual grasping and embodied-AI perception.
Key Features
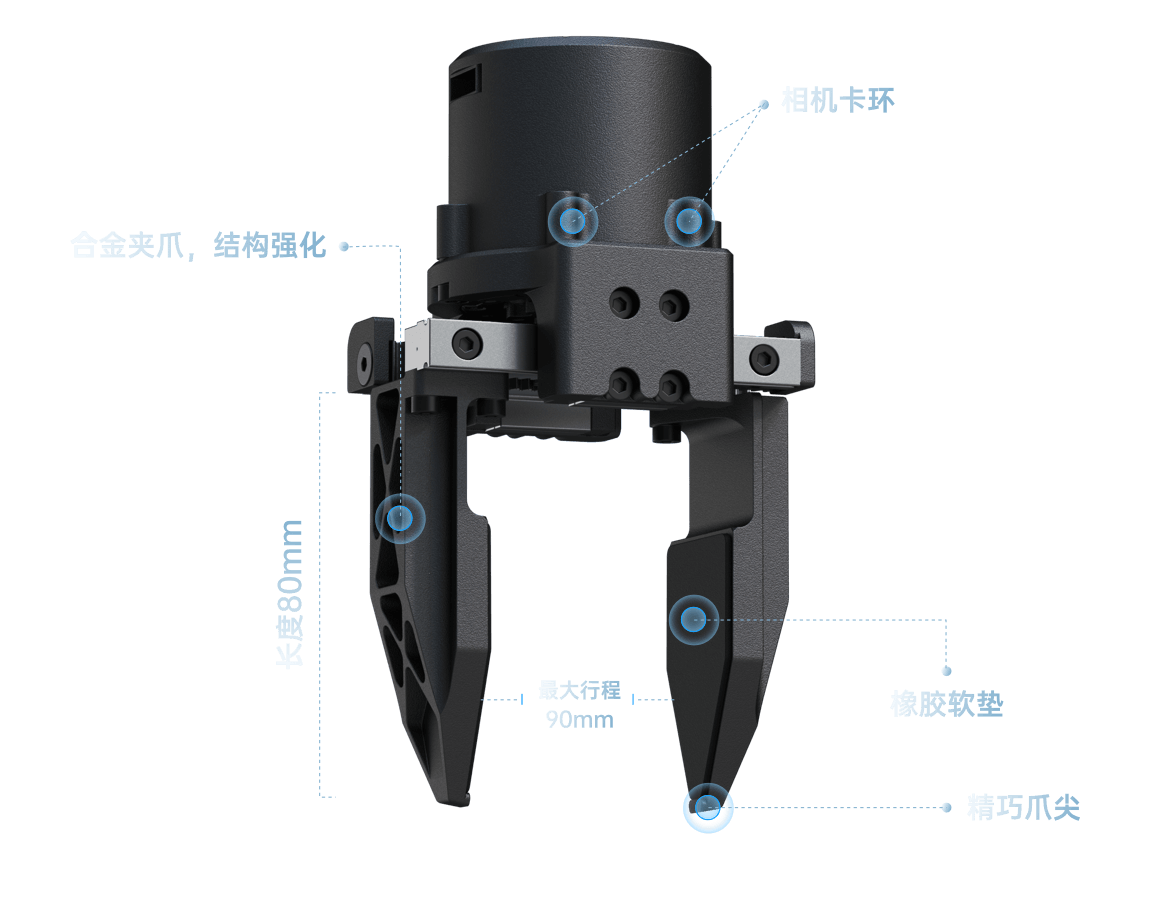
- Ultra-Long Stroke: A 90 mm maximum jaw opening lets one gripper handle a wide range of object sizes without swapping end effectors.
- Powerful, Adjustable Grip: A built-in Unitree joint motor delivers up to 120 N of clamp force, adjustable from 5 N to 120 N to suit delicate parts or heavy loads.
- High-Precision Operation: 0.1 mm positioning resolution and jaw speeds up to 150 mm/s support fast, repeatable pick-and-place cycles.
- Full Motion Control Modes: Supports position, speed, torque, stiffness, and damping control commands for both compliant and rigid grasping strategies.
- Professional-Grade Construction: Reinforced alloy claws, replaceable rubber-padded fingertips, and an integrated camera mount on the Advanced version are built for continuous embodied-AI operation.
Specifications
| Item | Specification |
|---|---|
| Product Name | Unitree Dex1-1 Parallel Gripper |
| Gripper Type | 2-Finger Parallel Gripper |
| Weight | 550 g |
| Dimensions | 143 × 78 × 67 mm |
| Maximum Stroke | 90 mm |
| Grip Force | 5–120 N (adjustable) |
| Positioning Resolution | 0.1 mm |
| Max Jaw Speed | 150 mm/s |
| Fastest Full-Stroke Close | 0.24 s |
| Motor Torque | 5 N·m |
| Max Motor Speed | 27 rad/s |
| Communication | RS485, 6 Mbps, 1000 Hz update rate |
| Operating Voltage | 24V–64V |
| Peak Current | 3.5 A |
| Reduction Ratio | 1:25 |
| Encoder Resolution | 15-bit |
| Operating Temperature | -20°C to 60°C |
| Versions | Standard / Advanced (built-in camera) |
| Compatible Robots | Unitree G1, H2, R1 (or standalone robotic arms) |
Standard vs. Advanced (Camera) Version
The Standard Dex1-1 is a bare parallel gripper for teams that already have vision or planning handled elsewhere on the robot. The Advanced version adds a compact onboard camera module directly above the jaws, giving the gripper its own close-range view of the object being grasped — useful for visual servoing, grasp verification, and embodied-AI pipelines that benefit from a wrist-level camera perspective.
Compatible Humanoids & Robotic Arms
The Dex1-1 mounts to the Unitree G1, H2, and R1 humanoid platforms in place of the standard end effector, and its standard circular bolt pattern also lets it mount to many third-party robotic arms. It suits G1 units such as the G1 Basic and G1 EDU-tier robots like the G1 EDU Standard-U1, as well as R1 units including the R1 Basic and R1 EDU Standard Edition. Teams that need finer, multi-finger dexterity rather than a parallel grip should also consider the Dex2/5 tendon-driven hand.
Installation & Use Cases
The Dex1-1 mounts to the robot wrist as a drop-in replacement using its standard bolt circle, without modifying the arm’s core hardware. Its RS485 interface and 1000 Hz update rate integrate directly with Unitree’s existing control stack, and the adjustable 5–120 N grip force lets one gripper move from delicate components to heavier payloads simply by changing the force setpoint.
This makes the Dex1-1 a good fit for electronics assembly and pick-and-place, courier and warehouse package sorting, retail shelf and vending-machine restocking, industrial automation lines, and manipulation research. Teams pairing the Dex1-1 with onboard AI compute, such as the G1 Docking Station, can run local inference for grasp planning directly on the robot.
Who Should Consider This Upgrade
This accessory suits robotics labs, universities, and research teams running G1, H2, or R1 units for pick-and-place, sorting, or industrial-automation work where a fast, adjustable-force parallel gripper is more practical than a full dexterous hand. Integrators building embodied-AI demos will also benefit from the Advanced version’s onboard camera. Grip force, stroke, and mounting details vary by robot configuration, so reach out to our team with your robot model before purchasing.