Why Add the Unitree Dex3-1 to Your G1?
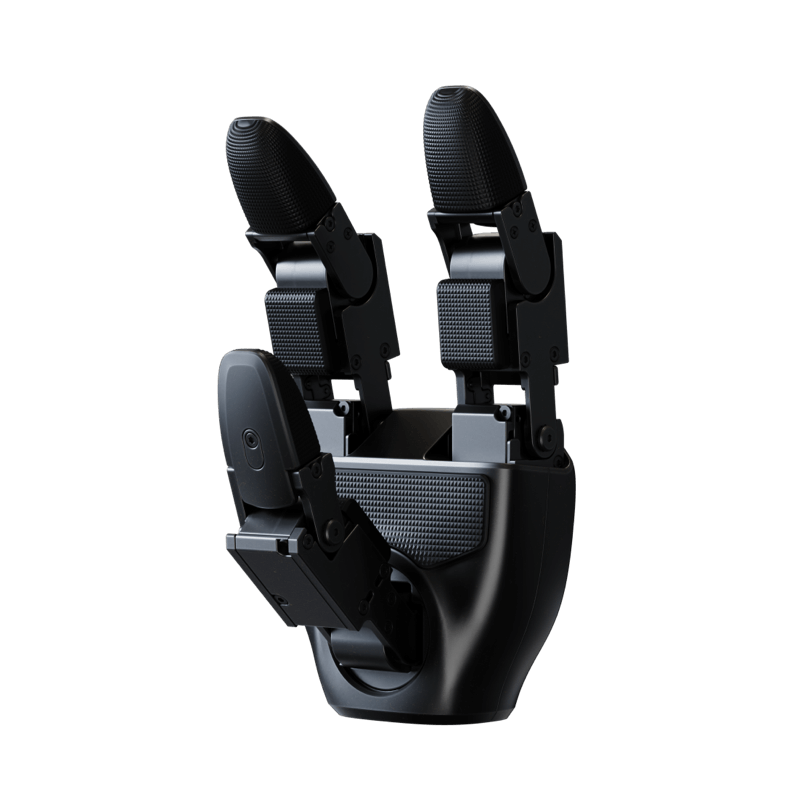
The Unitree Dex3-1 is a three-finger, force-controlled dexterous hand built specifically for the Unitree G1 humanoid. It packs 7 degrees of freedom across direct-drive micro brushless joints and 33 tactile sensors into a single 710 g hand, giving G1 both fine motion control and real touch feedback for precision manipulation. Full specifications are published on Unitree’s official product page.
Where the Dex2/5 uses a lightweight tendon-rope transmission and the Dex5-1 maximizes finger count for close-to-human dexterity, the Dex3-1 is Unitree’s direct-drive, force-controlled option — every joint is driven straight by a micro brushless motor rather than a tendon, and the hand carries the densest tactile sensor array of the three. It is purpose-built for the G1 platform only.

Key Features
- Direct-Drive Force Control: 7 degrees of freedom across 6 direct-drive micro brushless force-controlled joints plus 1 gear-driven force-controlled joint, giving accurate position AND force control with no tendon backlash.
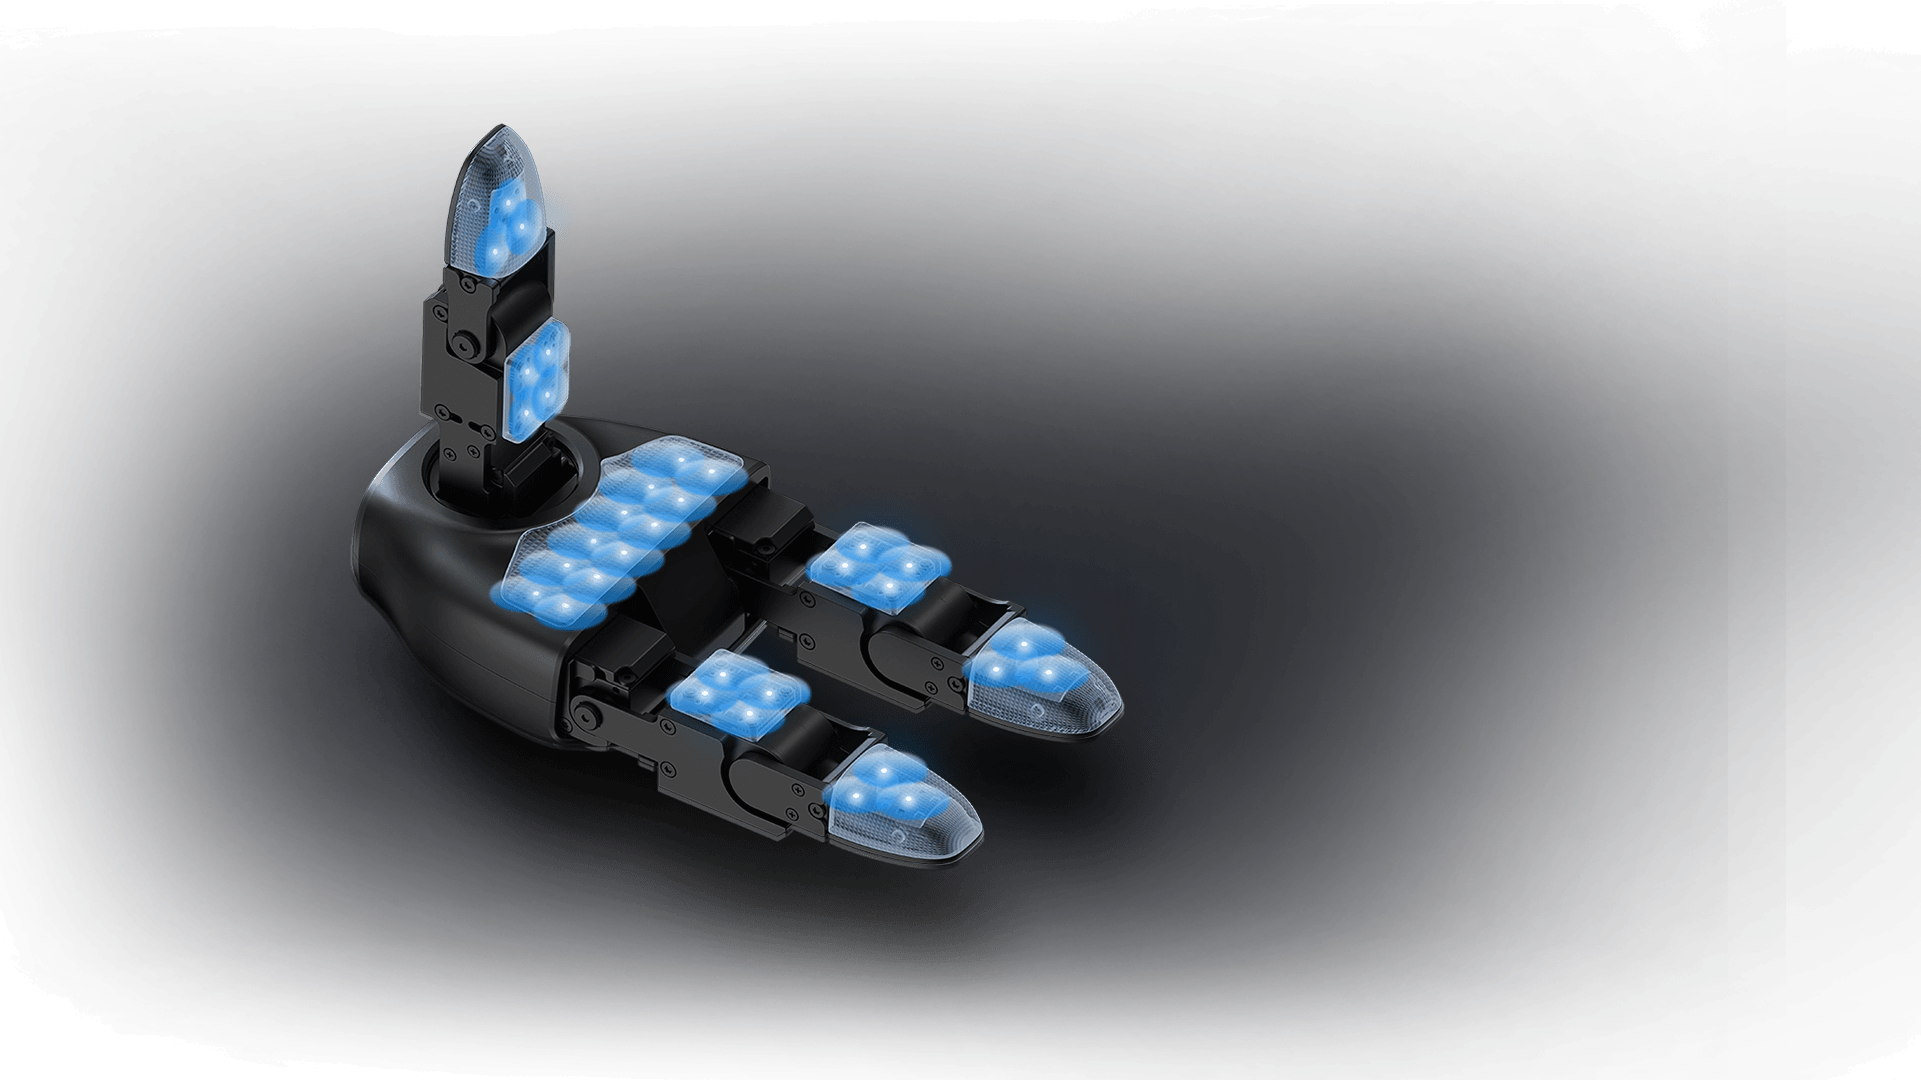
- Dense Tactile Sensing: 33 pressure sensors across 9 sensor arrays on the palm, finger pads, and fingertips, sensing loads from 10 g to 2500 g per point and tolerating up to 20 kg without damage.
- Precise, Repeatable Grip: ±2 mm fingertip repeat positioning accuracy, up to 500 g payload, and up to 400 W of peak power per grasp (3-second rating).
- Full Joint & Tactile Feedback: Reports joint mode, position, velocity, torque, temperature, voltage, and current, plus per-sensor pressure and temperature values and IMU data, all at a 1000 Hz update rate.
- Compact, Purpose-Built for G1: At 710 g and 175 × 88 × 77 mm, the Dex3-1 is sized and engineered specifically as a drop-in three-finger hand for the Unitree G1 humanoid.
Specifications
| Item | Specification |
|---|---|
| Product Name | Unitree Dex3-1 Dexterous Hand |
| Hand Type | Three-Finger Force-Controlled Dexterous Hand |
| Degrees of Freedom | 7 (6 direct-drive + 1 gear-driven force-controlled joints) |
| Weight | 710 g |
| Dimensions | 175 × 88 × 77 mm |
| Finger Configuration | Thumb (3 DOF), Index Finger (2 DOF), Middle Finger (2 DOF) |
| Fingertip Repeat Positioning Accuracy | ±2 mm |
| Load Capacity | 500 g max (palm down or palm left), 5 cm round rigid object |
| Peak Power | Up to 400 W @ 3 s |
| Operating Voltage | 12V–58V |
| Static Current | 0.2 A @ 58V |
| Max Current | 10 A |
| Communication | USB 2.0, 1000 Hz update rate |
| Operating Temperature | -20°C to 60°C |
| Tactile Sensors | 33 total (9 sensor arrays: palm, finger pads, fingertips) |
| Tactile Sensing Range | 10 g–2500 g per point |
| Max Safe Load (Tactile Sensors) | 20 kg without damage |
| Compatible Robots | Unitree G1 (only) |
Force-Controlled Joints & Tactile Sensing
The Dex3-1’s 7 joints are driven by two sizes of Unitree’s self-developed micro brushless force-controlled joint: an F-1515-108 (1:108 reduction, up to 0.76 Nm ideal torque, 23 rad/s max speed) and an F-1515-214 (1:214 reduction, up to 1.498 Nm ideal torque, 11 rad/s max speed), each weighing just 45 g and communicating over a high-speed single bus at 1000 Hz with absolute rotor encoders. Because every joint is force-controlled rather than tendon-driven, the hand can hold a target stiffness or damping as well as a target position.
Layered on top of that motion control, 9 tactile sensor arrays — 2×2 on the palm, 2×2 on each finger pad, and 3×1 on each fingertip — deliver 33 individual pressure points reporting 10 g to 2500 g of force each. That combination of joint-level force control and fingertip-level tactile feedback is what sets the Dex3-1 apart from Unitree’s other dexterous hands, and makes it a strong fit for grasp-force learning and delicate manipulation research.
Compatible G1 Models
The Dex3-1 is purpose-built for the Unitree G1 humanoid platform and mounts in place of the standard end effector. It suits G1 units such as the G1 Basic and G1 EDU-tier robots like the G1 EDU Standard-U1. Unlike the Dex2/5 and Dex5-1, it is not offered for the R1 or H2 platforms. Teams that need full five-finger dexterity should consider the Dex5-1 instead; teams that need only a simple two-finger grasp should consider the Dex1-1.
Installation & Use Cases
The Dex3-1 mounts to the G1 wrist as a drop-in replacement for the robot’s default hand or gripper, without modifying the arm’s core hardware. Its USB 2.0 interface and 1000 Hz update rate integrate directly with Unitree’s existing G1 control stack, and its combined joint and tactile feedback stream gives higher-level software real grasp-state awareness rather than blind position control.
This makes the Dex3-1 a strong fit for fine assembly and tool-use tasks such as soldering or small-part handling, tactile reinforcement-learning research, grasp-force and slip-detection studies, and any embodied-AI project where G1 needs to feel what it is holding rather than just move to a position. Teams pairing the Dex3-1 with onboard AI compute, such as the G1 Docking Station, can run local inference for tactile-informed grasp planning directly on the robot.
Who Should Consider This Upgrade
This accessory suits robotics labs, universities, and research teams running G1 units for manipulation research where force control and dense tactile feedback matter more than raw finger count — grasp-force learning, delicate object handling, and slip-aware grasping are all strong fits. Because the Dex3-1 is currently offered only for G1, confirm your G1 configuration with our team before purchasing.