Why Add the Unitree Dex5-1 to Your Humanoid?
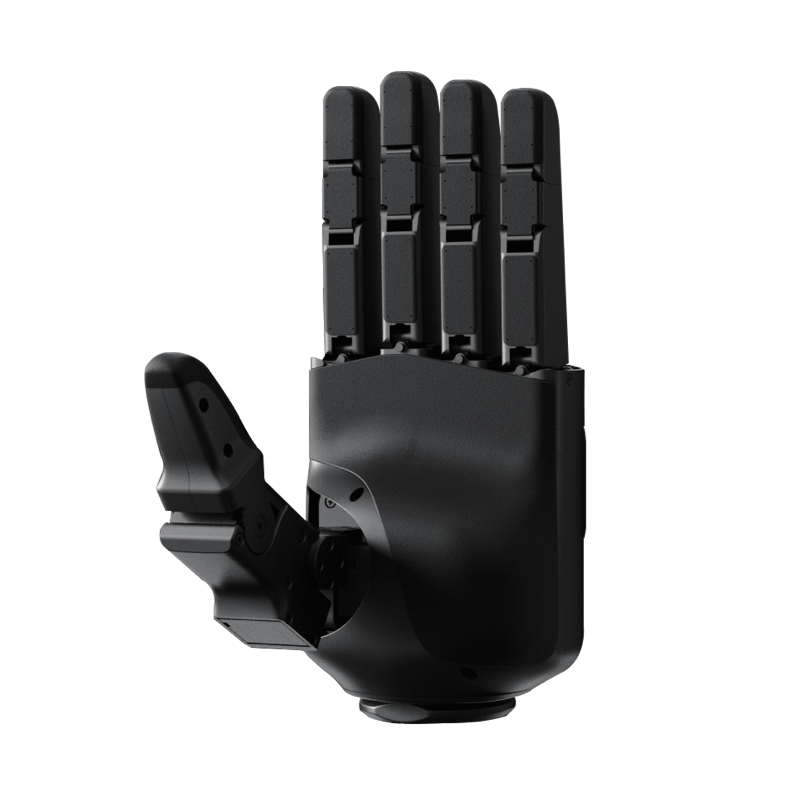
The Unitree Dex5-1 is a five-fingered dexterous hand built for humanoids that need close-to-human manipulation, not just a basic grip. With 20 degrees of freedom, it can perform fine, coordinated finger movements — Unitree’s own demos show it solving a Rubik’s cube. Full specifications are published on Unitree’s official product page.
The Dex5-1 sits above the tendon-driven Dex2/5 in dexterity, trading some of that hand’s ruggedness for a much larger range of independent finger motion. It ships in a Standard version and a Dex5-1P version that adds full-hand tactile sensing for grasp force feedback.

Key Features
- Ultra-High Dexterity: 20 degrees of freedom (16 active + 4 passive) across five independent fingers enable complex, human-like manipulation tasks.
- Smooth, Backdrivable Actuation: 12 self-developed micro force-controlled composite transmission joints plus 4 gear transmission joints, driven by high-power-density hollow-cup motors, eliminate the stiff, jerky feel of typical robotic hands.
- Precise, Capable Grip: Up to 10 N of fingertip force, ±1 mm fingertip repeat positioning accuracy, and a load capacity of up to 4.5 kg.
- Independent Finger Replacement: All five fingers can be replaced independently, keeping maintenance and repair costs down after wear or damage.
- Full Motion & Sensor Feedback: Reports joint mode, position, velocity, torque, temperature, voltage, current, and IMU data, with support for reinforcement-learning training pipelines.
Specifications
| Item | Specification |
|---|---|
| Product Name | Unitree Dex5-1 Dexterous Hand |
| Hand Type | Five-Fingered Dexterous Hand |
| Degrees of Freedom | 20 (16 active + 4 passive) |
| Weight | 1100 g |
| Dimensions | 217.3 × 127.5 × 72.1 mm |
| Finger Configuration | Thumb (4 DOF) + four fingers (3 DOF each) |
| Minimum Grip Diameter | 10 mm |
| Fingertip Force | Up to 10 N |
| Fingertip Repeat Accuracy | ±1 mm |
| Load Capacity | 3.5 kg (palm down) / 4.5 kg (palm left), 5 cm round object |
| Joint Transmission | 12 micro force-controlled composite joints + 4 gear transmission joints |
| Motor Type | High-power-density hollow-cup motor |
| Operating Voltage | 24V–60V |
| Current Draw | 0.2 A static / 4 A max @ 58V |
| Communication | USB 2.0, 1000 Hz update rate |
| Operating Temperature | -20°C to 60°C |
| Versions | Dex5-1 (Standard) / Dex5-1P (tactile sensing) |
| Compatible Robots | Unitree G1, H2, R1 |
Standard vs. Dex5-1P (Tactile Sensing) Version
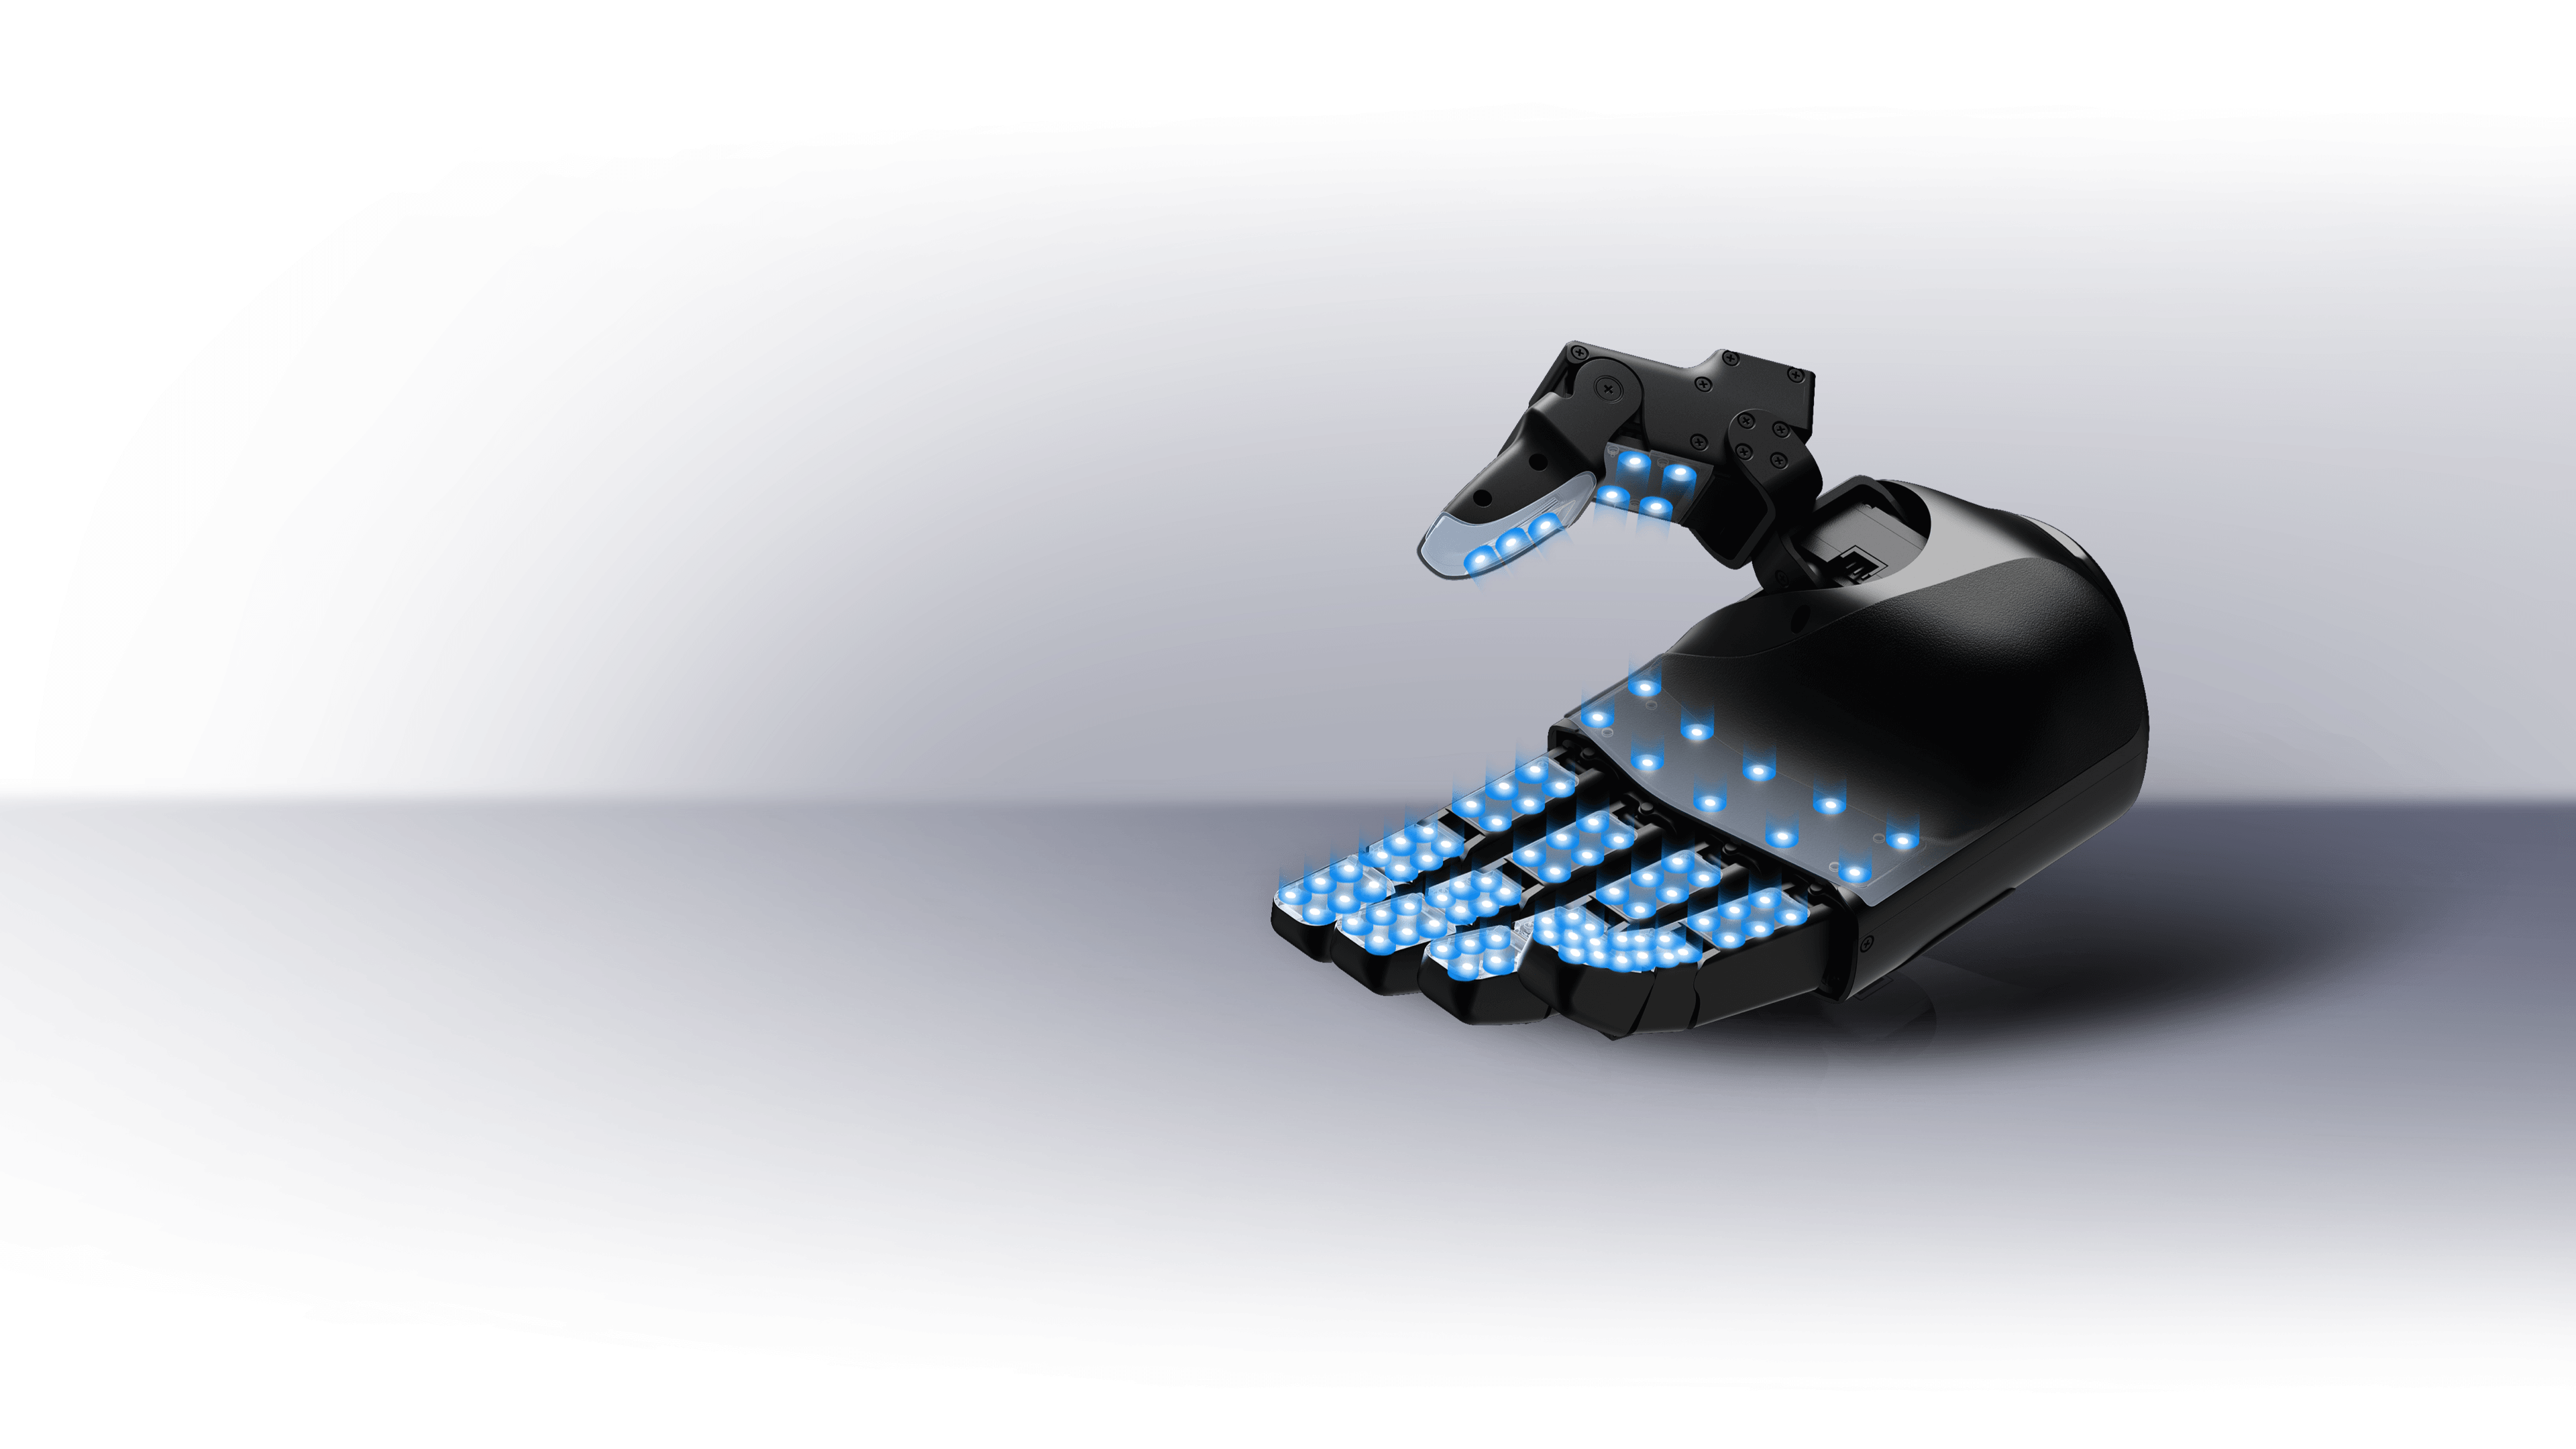
The Standard Dex5-1 delivers the full 20-DOF dexterity and motion feedback described above. The Dex5-1P variant adds 94 pressure sensors spread across the palm and all five fingers, sensing loads from 10 g up to 2500 g per point and tolerating a maximum safe load of 20 kg without damage. That gives grasp-force feedback in addition to joint data — useful for delicate object handling, slip detection, and tactile reinforcement-learning research.
Compatible Humanoids
The Dex5-1 mounts to the Unitree G1, H2, and R1 humanoid platforms in place of the standard end effector. It suits G1 units such as the G1 Basic and G1 EDU-tier robots like the G1 EDU Standard-U1, H2 units such as the H2 Basic, and R1 units including the R1 Basic and R1 EDU Standard Edition. Teams that need a simpler, faster parallel grip rather than full five-finger dexterity should consider the Dex1-1 or the tendon-driven Dex2/5 instead.
Installation & Use Cases
The Dex5-1 mounts to the G1, H2, or R1 wrist as a drop-in replacement for the robot’s default hand or gripper, without modifying the arm’s core hardware. Its independently replaceable fingers and backdrivable, low-damping joints are built to withstand the repeated contact and occasional collisions that come with manipulation research and reinforcement-learning training.
This makes the Dex5-1 a strong fit for embodied-AI and manipulation research, teleoperation studies, fine assembly and tool-use demonstrations, and any application where a parallel gripper’s two-finger grasp isn’t enough. Teams pairing the Dex5-1 with onboard AI compute, such as the G1 Docking Station, can run local inference for grasp planning directly on the robot.
Who Should Consider This Upgrade
This accessory suits robotics labs, universities, and research teams running G1, H2, or R1 units for advanced manipulation, dexterous grasping, or reinforcement-learning work where multi-finger control matters more than raw ruggedness. Teams focused on tactile sensing and slip-aware grasping should look specifically at the Dex5-1P. Grip force, dimensions, and mounting details vary by robot configuration, so reach out to our team with your robot model before purchasing.