

Why Choose the Unitree H2-A General Edition?
The Unitree H2-A General Edition is a fixed-base, dual-arm industrial humanoid built for high-precision manipulation work. With 19 degrees of freedom, a 120 N·m maximum arm-joint torque, and a fully in-house actuator and motion-control stack, it is designed as a stationary precision workstation rather than a mobile platform — ideal for fixed manipulation cells where consistent, repeatable positioning matters more than mobility.
H2-A shares its arms, sensing suite, and computing platform with the H2-D General Edition and H2-D Flagship Edition, but mounts on a compact fixed base instead of a chassis — making it the lightest and most budget-friendly way to bring Unitree’s dual-arm manipulation platform into a fixed workcell.
Key Features
- Fully In-House Technology Stack: Self-developed actuators, force-controlled joints, and motion-control algorithms built for secondary development and system customization.
- 19-DOF Dual-Arm Motion: 7 DOF per arm plus a 3-DOF waist and 2-DOF head, delivering a peak single-arm payload of ~15 kg (rated ~7 kg) and a 120 N·m maximum arm-joint torque.
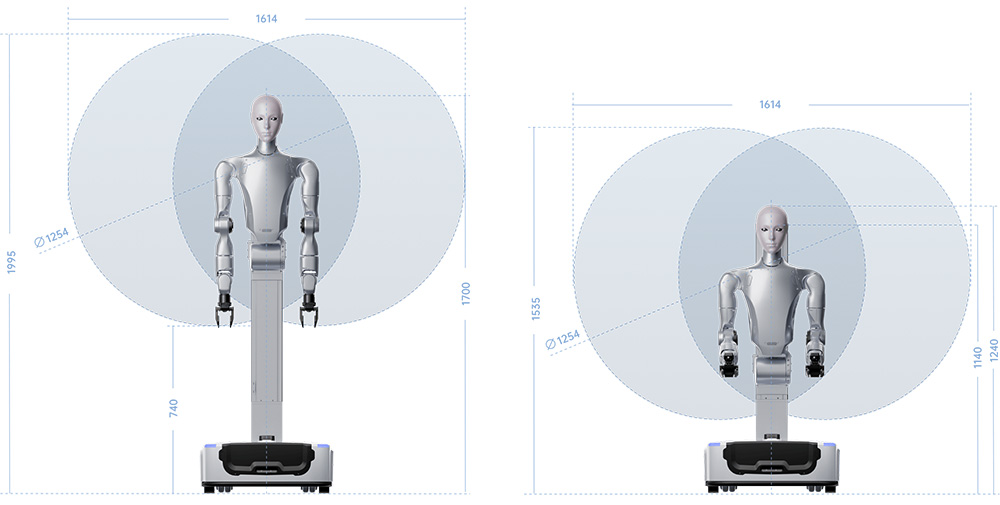
- Fixed-Base Precision Workstation: A compact 780 × 444 × 200 mm base and 34.4 kg total weight make H2-A the simplest way to deploy Unitree’s dual-arm platform in a stationary cell.
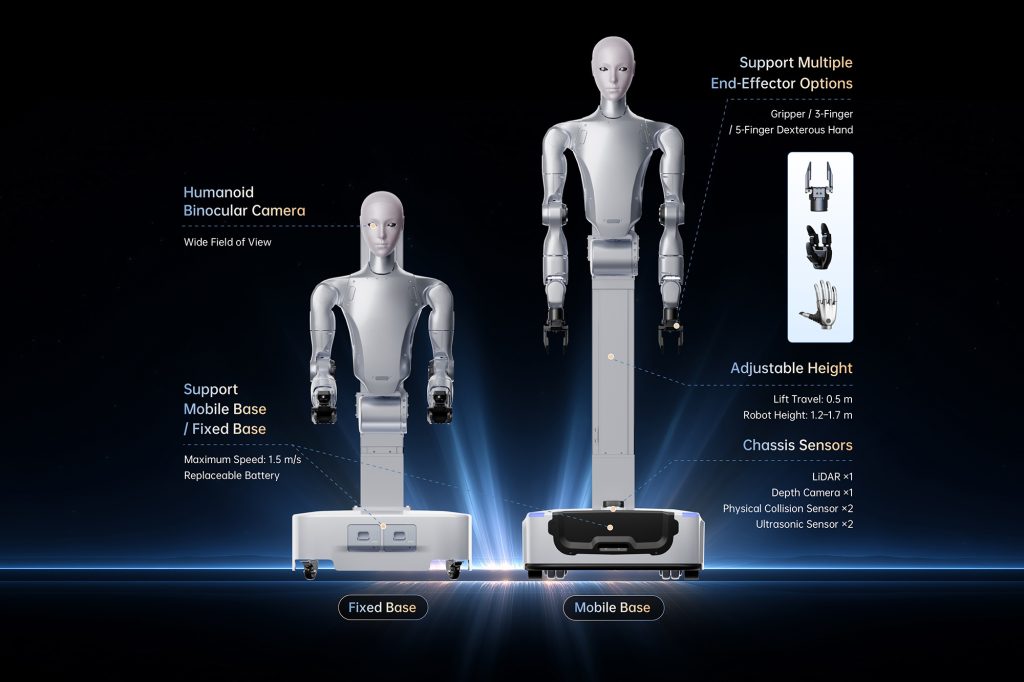
- Multimodal Perception: Wide field-of-view binocular vision plus a high-definition neck camera and array-microphone voice interaction for natural human-robot collaboration.
- Multi-Type End Effectors: Quick-change support for 2-finger grippers, 3-finger dexterous hands, or 5-finger dexterous hands to match different payload and dexterity requirements.
Specifications
| Item | Specification |
|---|---|
| Model | Unitree H2-A General Edition |
| Deployment | Fixed Base (Stationary) |
| Dimensions (W × D × H) | 780 × 444 × 200 mm |
| Total Weight (with Battery) | 34.4 kg |
| Total DOF (excl. end effector) | 19 |
| Per-Arm DOF | 7 |
| Waist DOF | 3 |
| Head DOF | 2 |
| Joint Output Bearings | Industrial-grade crossed roller bearings (high precision, high load capacity) |
| Joint Motors | Low-inertia, high-speed internal-rotor PMSM for fast response and better heat dissipation |
| Max Arm-Joint Torque | 120 N·m |
| Single-Arm Payload | Peak ~15 kg; Rated ~7 kg |
| End-Effector Options | 2-finger gripper / 3-finger dexterous hand / 5-finger dexterous hand (selectable) |
| Waist Range of Motion | Yaw ±155°; Pitch +25°/−30°; Roll ±30° |
| Single-Arm Reach (excl. end effector) | ~0.6 m |
| Chassis / Frame Material | Aerospace-grade aluminum + titanium alloy + high-strength engineering plastics |
| Cooling | Air cooling |
| Base Computing | PC1: Intel Core i5 (platform functions); PC2: Intel Core i7 (user development) |
| Perception Sensors | Wide-FOV humanoid binocular camera ×1; HD neck camera ×1 |
| Voice Interaction | Array microphone + high-power speaker |
| Connectivity | WiFi 6, Bluetooth 5.2 |
| Optional High-Compute Module | Multiple brands/models supported (e.g. NVIDIA Jetson Thor) |
| Battery | Quick-release battery, 75.6 V / 15 Ah (972 Wh) |
| Handheld Controller | Included |
| Runtime | Battery power: ~8 h (workload-dependent); DC power: continuous 24/7 |
| OTA Updates | Supported |
| Secondary Development | Full SDK / API support |
| Warranty | 12 months |
Fixed-Base Precision, Full Dual-Arm Dexterity
H2-A is built around the same self-developed force-controlled joints as the rest of the H2 series: industrial-grade crossed roller bearings paired with low-inertia, high-speed internal-rotor PMSM motors give each arm precise position and torque control up to 120 N·m. A 3-DOF waist (yaw ±155°, pitch +25°/−30°, roll ±30°) and 2-DOF head let the upper body reorient toward a workpiece without needing legs or a mobile base — ideal for a bench-mounted or cell-mounted manipulation station.
Sensing, Computing & Connectivity
- Vision: A wide field-of-view humanoid binocular camera plus a dedicated HD neck camera give H2-A stereo depth perception and close-up detail for fine manipulation tasks.
- Voice Interaction: An array microphone paired with a high-power speaker supports natural spoken commands and feedback on the factory floor.
- Base Computing: A dual-PC architecture separates platform functions (Intel Core i5) from user application development (Intel Core i7), and an optional high-compute module (multiple brands/models, including NVIDIA Jetson Thor) adds on-device AI inference for embodied-AI workloads.
- Connectivity: Built-in WiFi 6 and Bluetooth 5.2 support wireless integration with plant networks, teleoperation tools, and the included handheld controller.
End-Effector Options
H2-A’s wrists accept the same quick-change end effectors used across Unitree’s humanoid line, so integrators can match the hand to the task: the Dex1-1 2-finger parallel gripper for fast pick-and-place, the Dex3-1 3-finger force-controlled hand for tactile precision work, or a 5-finger dexterous hand such as the Dex5-1 for close-to-human dexterity. Contact our sales team to confirm the correct end-effector configuration for your application.
Applications & Use Cases
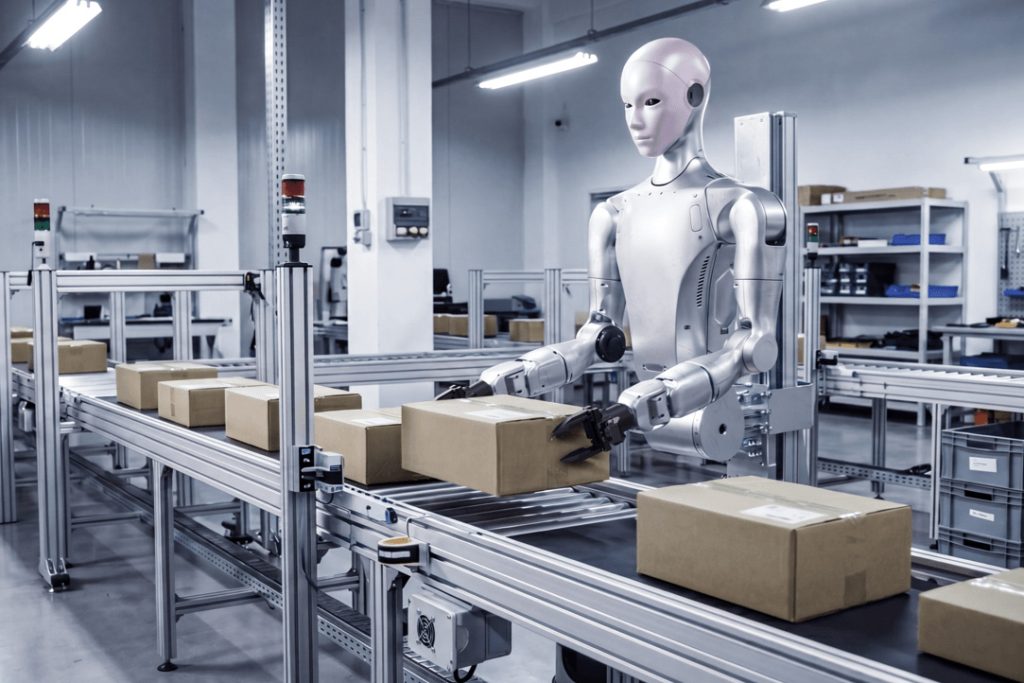
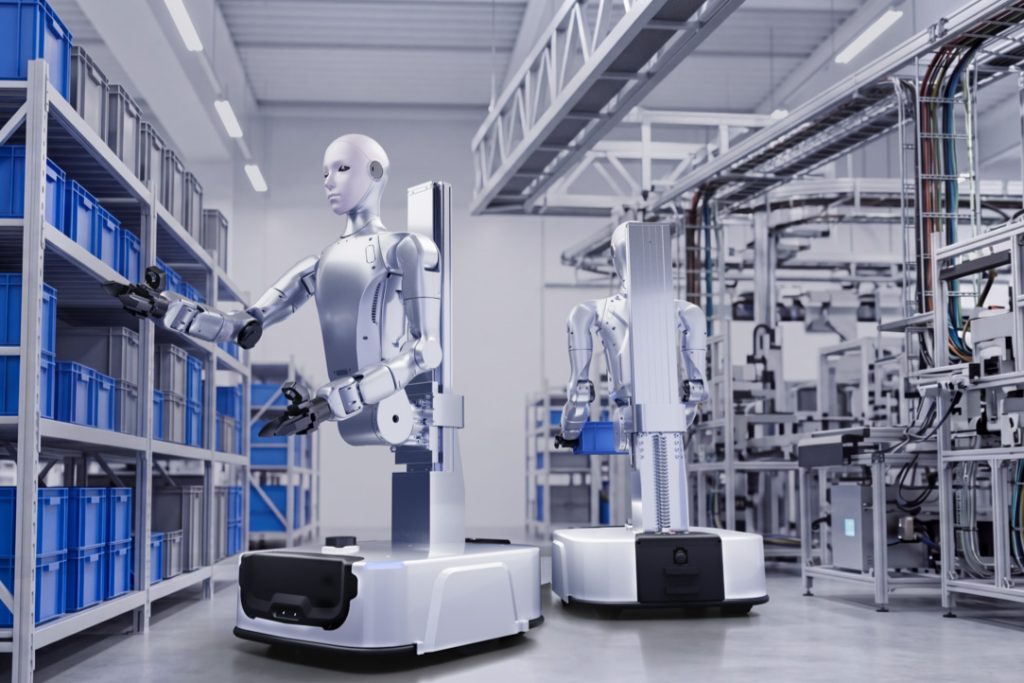
- Industrial Manipulation Cells: Fixed-position assembly, kitting, part feeding, and inspection tasks where a stationary dual-arm platform outperforms a single-arm robot.
- Embodied AI Research: A cost-effective, fully in-house-controlled platform for teams researching manipulation policies, tactile learning, and human-robot interaction without the added complexity of a mobile chassis.
- Robotics Education: A compact, bench-mountable dual-arm humanoid for teaching manipulation, robotics, and embodied-AI curricula.
Who Should Consider This Robot
H2-A General Edition suits manufacturers, integrators, and research labs that need genuine dual-arm manipulation in a fixed work cell without paying for mobility they won’t use. If your application requires the robot to move between stations, consider the H2-D Flagship Edition instead. Contact our team to confirm end-effector selection and integration requirements before ordering.